One base under every robot.
ZIV is a compact autonomous base with all-wheel drive and steering, a 48 V power system, a safety controller and a universal payload interface. Everything above it is a module.
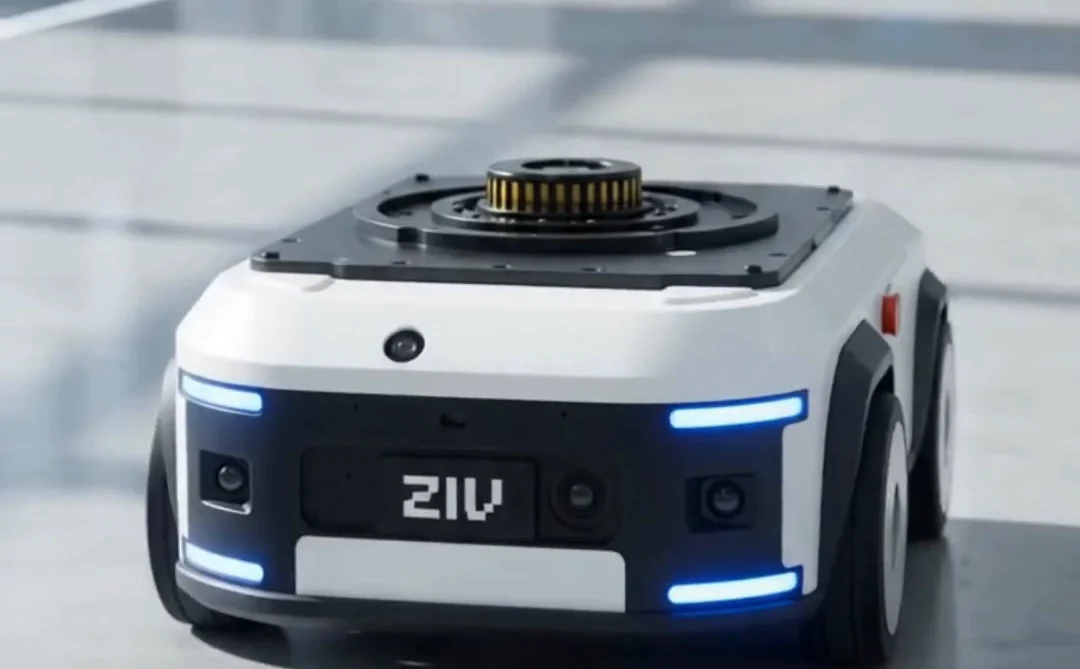
Small enough for corridors. Wide enough to stand a person's height on.
Prototype reference. The humanoid module adds a torso to about 5 ft (1.52 m) overall.
Prototype reference dimensions. Subject to change before release.
Tap through the cutaway.
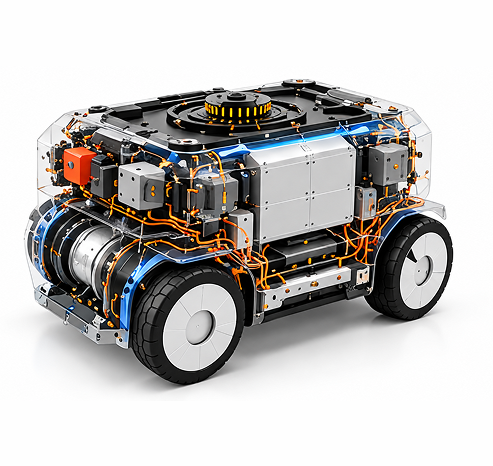
The base sees the room and protects itself.
Stereo RGB camera
Object recognition and people detection at the front of the base.
3D depth camera
Depth perception for navigation and obstacle shapes.
Safety LiDAR
360° obstacle detection with configurable safety zones.
Ultrasonic sensors
Low-height and close objects that cameras and LiDAR can miss.
Emergency stop
Hard-wired buttons front and rear, independent of software.
LED ring
Colour and motion show what the robot is doing, readable from across a room.
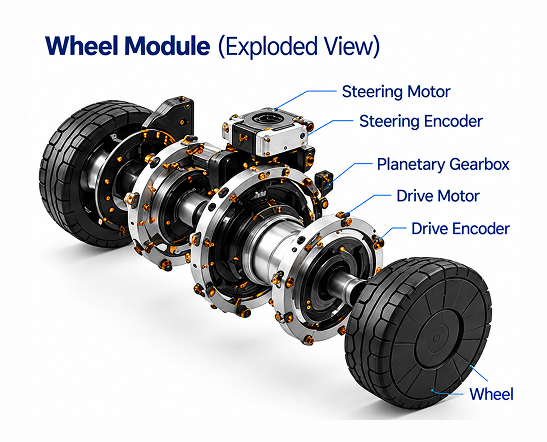
Four independent wheels. Drive and steer in one unit.
A steering motor and encoder sit above a planetary gearbox, drive motor and encoder. The same module is used at every corner, which keeps spares and service simple.
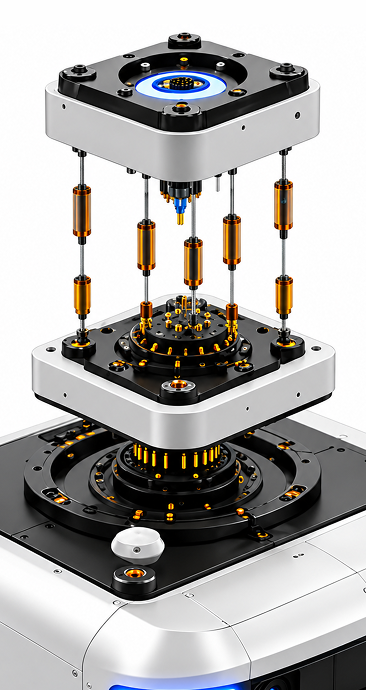
Swap a robot in minutes.
A module drops onto the top plate, locks in four places and announces itself. The base reads the module, loads the matching safety profile and powers up the payload.
- Four mechanical locks
- 48 V power connector
- Ethernet and CAN-FD data
- Safety interlock that refuses to power an unlocked module
- Automatic module detection by RFID
Aluminium where it carries load. Plastic where it does not.
The chassis is a 40-series aluminium profile frame with standard brackets, plates and fasteners, so a small team can build, repair and re-spin it without special tooling. The shell is 3D printed, which lets us change the look of a module without touching the structure.